Electrical Engineering Student

Seri Khoury

I am building my skills in PCB design, embedded hardware, power systems, and board layout.

Download my resume
Seri Khoury in a suit and tie
khouryseri@gmail.com ↗734-895-5053Livonia, MILinkedIn profile ↗University of Michigan-Dearborn ↗

About me

I am an Electrical Engineering student at the University of Michigan-Dearborn. I like working on hands-on projects where I can go from a schematic to a working system. Through classes and engineering teams, I have been building my skills in Altium, KiCad, PCB layout, sensors, power systems, and debugging hardware.

Engineering Experience & Leadership

Michigan Aerospace Association (MASA) - UM-Dearborn

Airbrakes Team - Schematic Design

Jul 2026 - Present

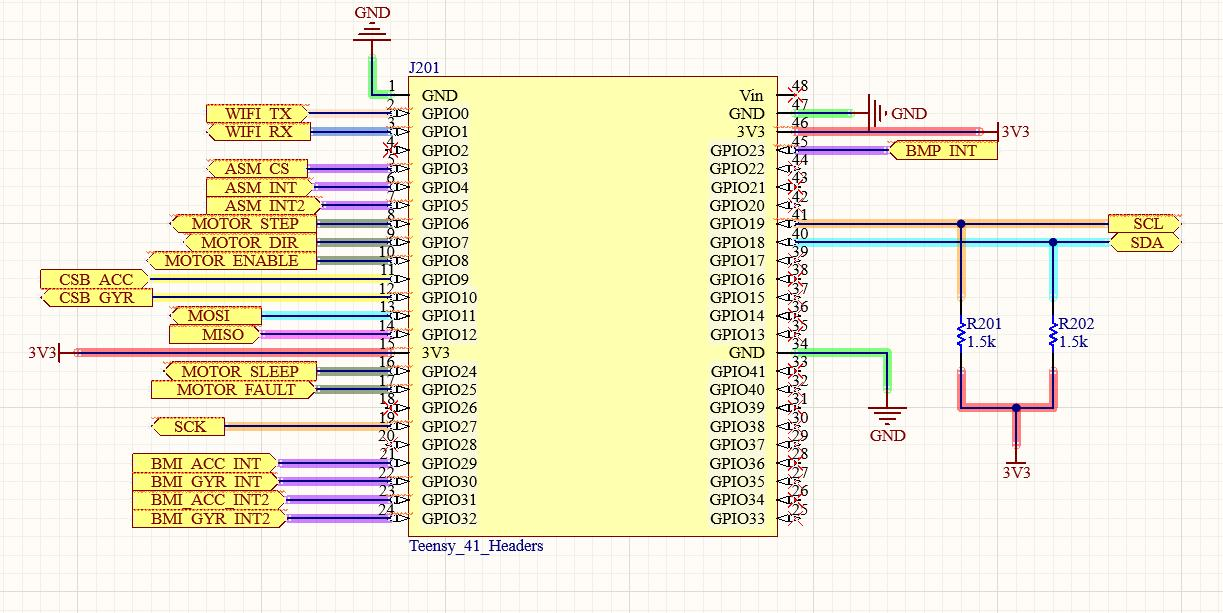
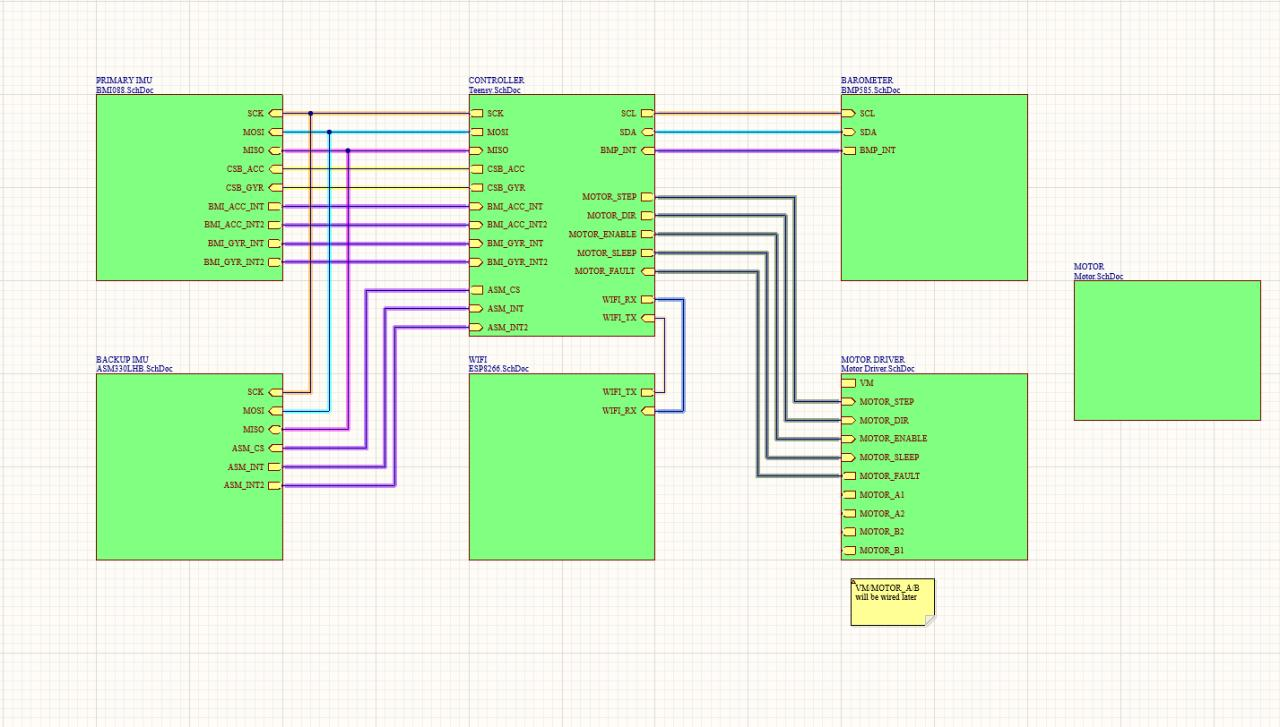
  • I contribute to the hierarchical Altium schematic for an airbrakes subsystem, organizing interfaces among the controller, sensors, wireless communication, motor driver, and motor.
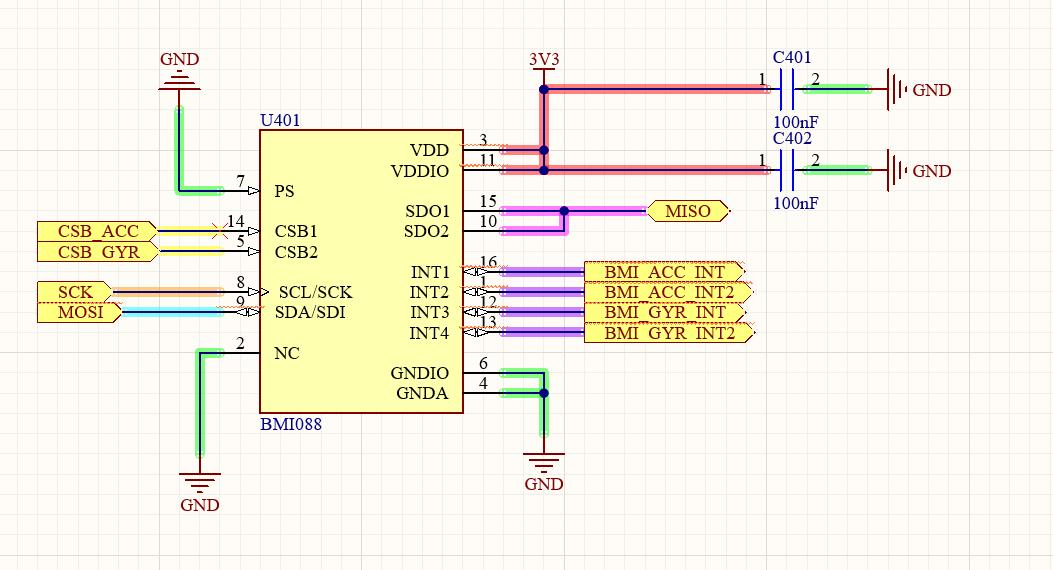
  • I document sensor and control connections, including SPI, I²C, UART, interrupt, power, and ground signals for team review and later PCB work.
Hack Dearborn 5

Operations Team Member

Apr 2026 - Present

  • I support a student-run hackathon by helping with setup, participant flow, communication, and troubleshooting.

Google Developer Groups on Campus - UM-Dearborn

Snow Elementary STEM Outreach Volunteer

Apr 2026

  • I helped run hands-on STEM activities focused on teamwork, signals, debugging, and introductory coding.

Amazing Mex Foods QDOBA

Cook / Line Server / Cashier

Jun 2023 - Aug 2025

  • I handled food preparation, customer service, transactions, and team coordination in a high-volume environment.

Education

University of Michigan-Dearborn ↗

Bachelor of Engineering in Electrical Engineering · GPA: 3.5 / 4.0

Relevant coursework: Calculus I-III, Physics I-II, Digital Systems, Circuits, Differential Equations, Signals and Systems, and Computer Methods for ECE.

Aug 2025 - Apr 2029
Dearborn, MI

Technical skills

Tools & strengths

PCB / ECAD

Altium Designer · KiCad · Schematic Capture · PCB Layout · Component Placement · Power & Signal Routing · DRC

Hardware

Arduino · Soldering · Oscilloscope · Sensors · DC-DC Converters · Power Supplies

Programming & CAD

C++ · Python · MATLAB · I²C · Fusion 360 · AutoCAD

Engineering projects

Projects

These projects show the skills I have been building in class and through engineering teams.

Altium · I²C · Deserializer · Power Protection

Multi-View Camera Interface PCB

I designed and built a multi-camera interface PCB for surround-view/ADAS applications. I routed camera inputs through a deserializer interface to an external processing board for calibration, distortion correction, and image stitching.

  • I completed schematic capture and PCB layout in Altium.
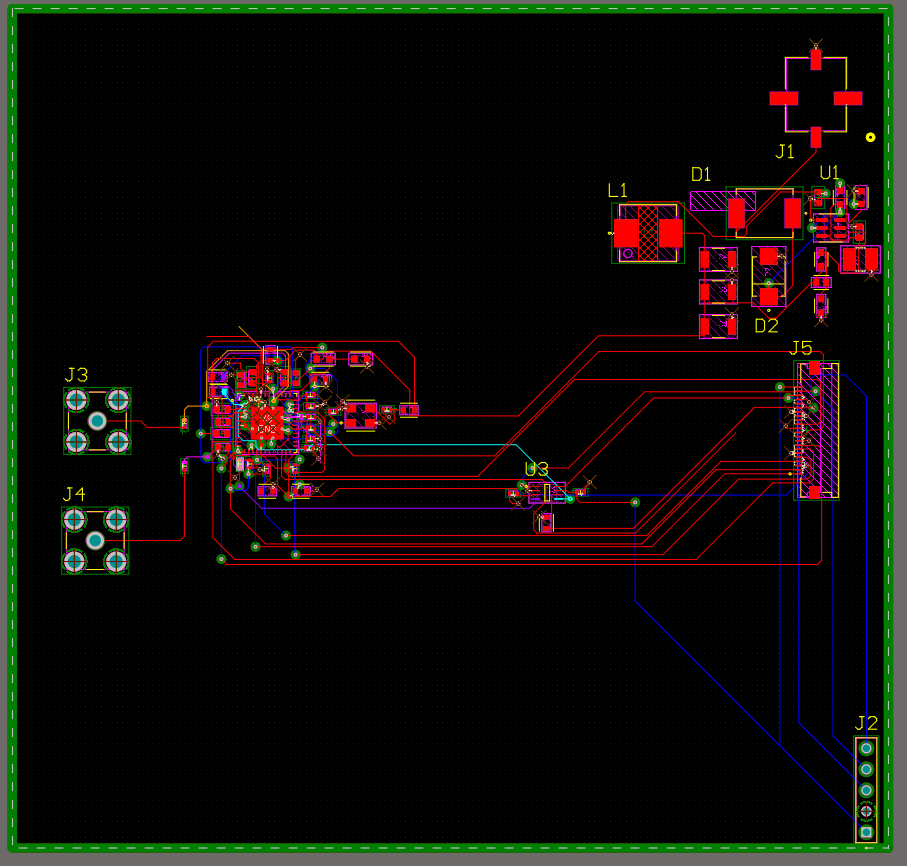
  • I integrated 1.8 V/3.3 V I²C level translation, LM74500-Q1 power protection, decoupling, connectors, a ground plane, and DRC-checked power and signal routing.

What I Learned: How to organize a PCB layout and route signals and power.

Altium PCB routing view of the multi-view camera interface board
PCB routing view - Multi-View Camera Interface PCB, August 2026.

Altium · Embedded control · Sensors · Motor control

MASA Airbrakes System Design

I helped work on the hierarchical schematic for a rocket airbrakes subsystem. It organizes the sensors, controller communication, motor driver, and motor connections into separate sheets that are easier for the team to review.

  • I mapped the primary IMU, backup IMU, barometer, controller, Wi-Fi, motor driver, and motor interfaces.
  • I used clear net labels and hierarchical ports to make the design easier for teammates to review and route later.

What I Learned: How to use hierarchical sheets, name signals clearly, and connect sensors and control hardware in one system.

Arduino · C++ · Sensors · CAD

Autonomous Robot

Team Lead · October 2025 - December 2025

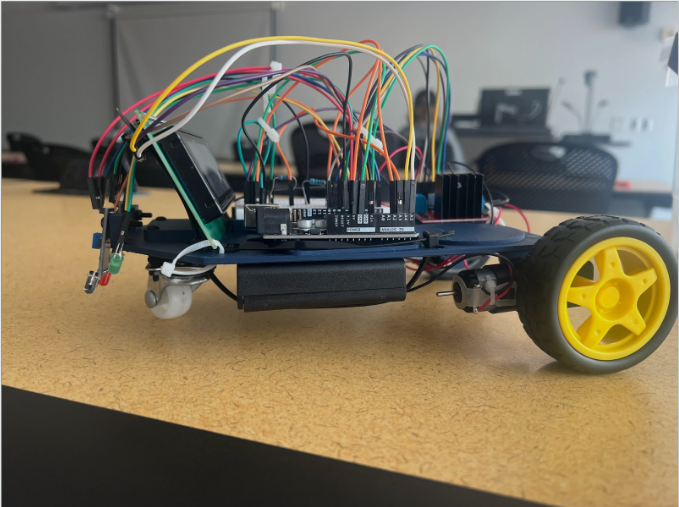
  • I led a four-member team to design and build an autonomous robot for obstacle detection and path correction, assigning mechanical, electrical, and programming tasks from concept through prototype.
  • I programmed sensor-feedback motion logic in C++ and debugged the wiring, motor response, and control behavior until the robot completed repeatable movement trials.

What I Learned: How to lead a small team, use sensor feedback in code, and test and debug a physical prototype.

Autonomous robot built by Seri Khoury's team with an Arduino, sensors, motors, and wiring
Autonomous robot built by my four-person team.

Contact

Let’s connect.

Livonia, Michigan · 734-895-5053 · LinkedIn ↗